Engineering
Useful thrust starts with the whole system.
Marine propulsion must balance force, weight, energy and sound. We develop EP1's motor, blades and control together around that challenge.
Scroll to explore EP1
Thrust, weight and quietness. Engineered together.
Uncrewed surface vehicles
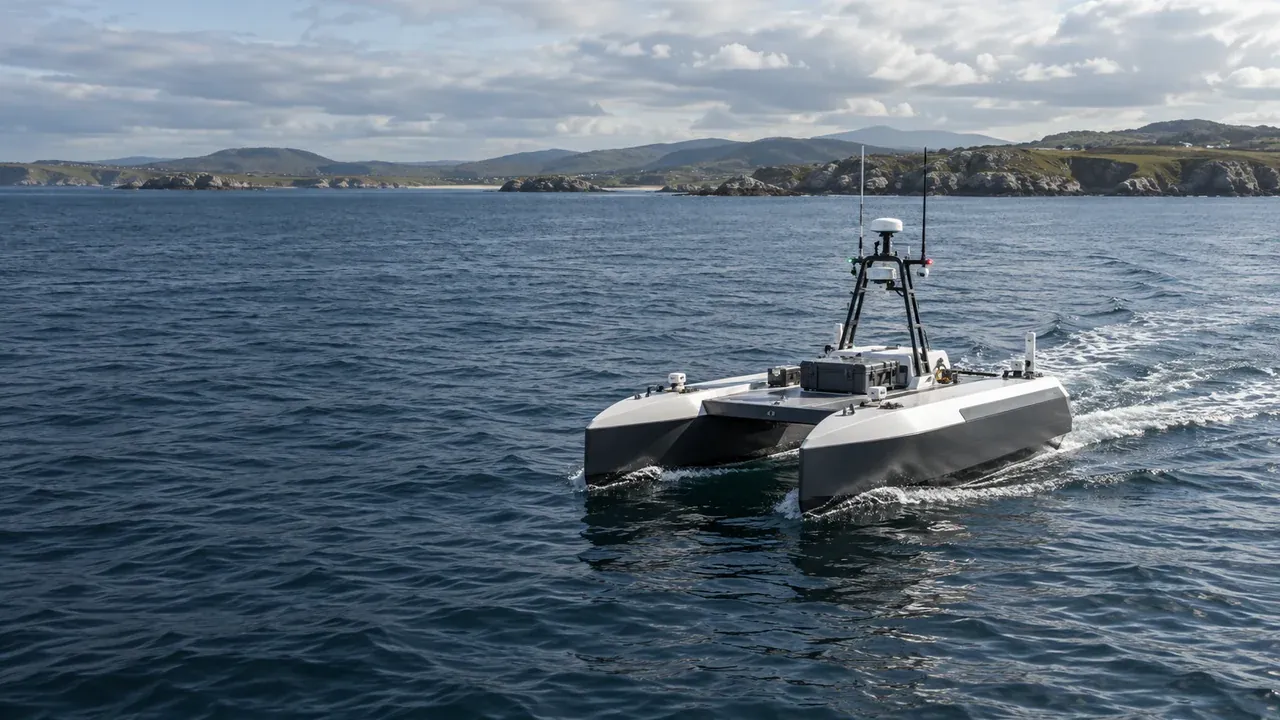
We develop EP1 for sustained thrust against current and wind. Its shaftless centre removes a wrapping point for line and weed during uncrewed operations.
Autonomous underwater vehicles
We develop motor, blades and control around low cruise-energy demand and low self-noise, supporting long missions and sensitive acoustic payloads.
Remotely operated vehicles
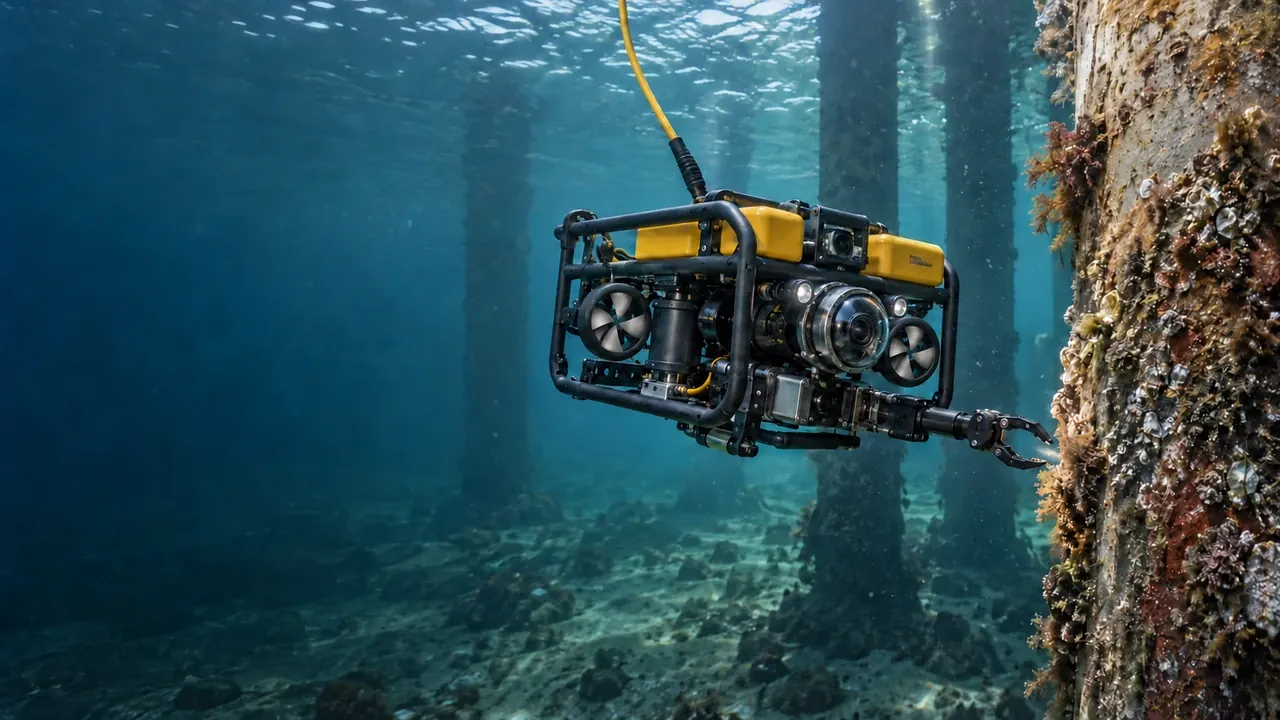
We develop sustained thrust and responsive control around current, tether and tool loads, helping underwater robots hold position and apply force where the work demands it.
Small electric boats
Our portable-drive work pairs EP1 with a tiller and removable battery, balancing useful thrust, energy for the trip, quiet operation and the weight you carry.
Loading EP1
EP1 / Band detail
Engineering
Marine propulsion must balance force, weight, energy and sound. We develop EP1's motor, blades and control together around that challenge.
Scroll to explore EP1
Whole-vehicle design
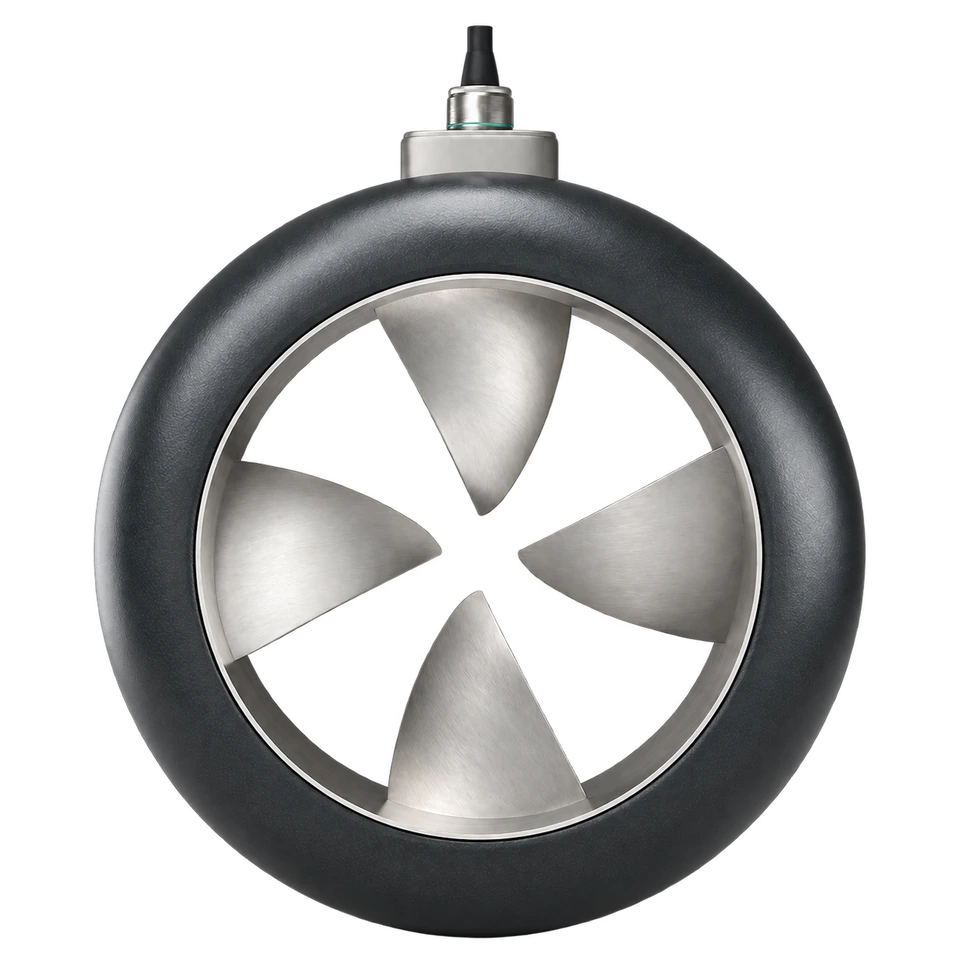
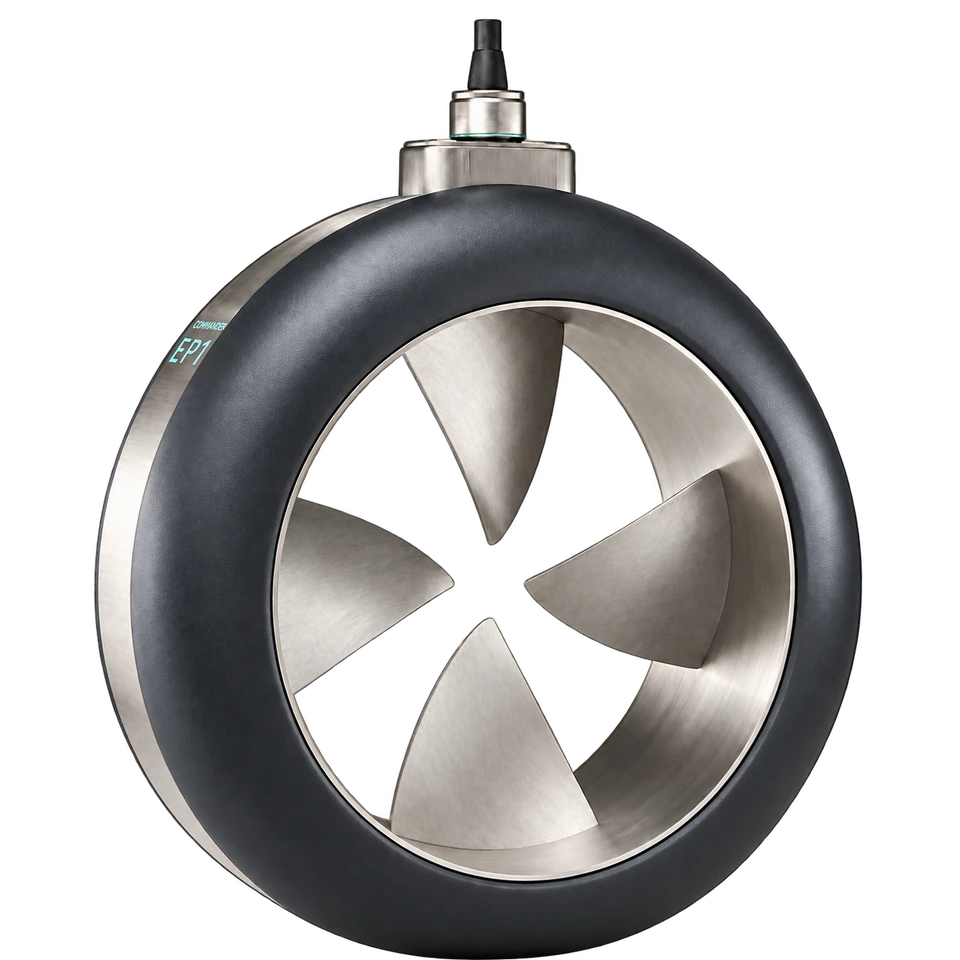
EP1 brings axial-flux motor design and shaftless propulsion together around the useful output your vehicle needs.
Shaftless rim drive
Drive at the rim changes the propulsion layout. Our motor, blade and control work addresses its behavior in water.
Axial-flux architecture
In an axial-flux motor, the magnetic field crosses the active gap along the rotation axis, supporting a disc-like form.
Integrated assembly
The inlet, motor ring, rotor and outlet form one assembly, developed alongside dedicated control.
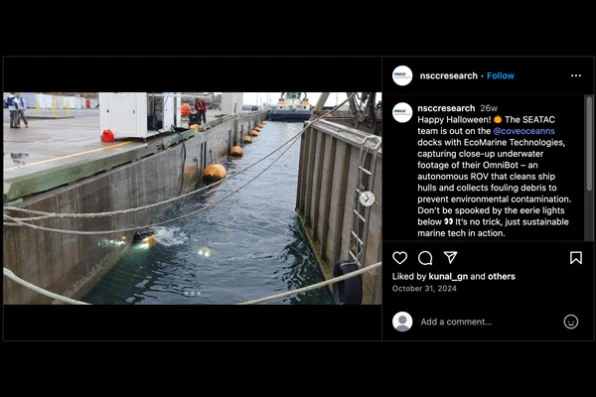
Powered by EP1, OmniBot is EcoMarine's flagship ROV for underwater fouling removal and surface cleaning. Designed for heavy marine growth, it combines maneuverability in currents with sustained thrust for surface work.
As IMO develops mandatory biofouling requirements, Canada is helping shape the framework. OmniBot combines underwater inspection and cleaning to help vessel operators manage marine growth.
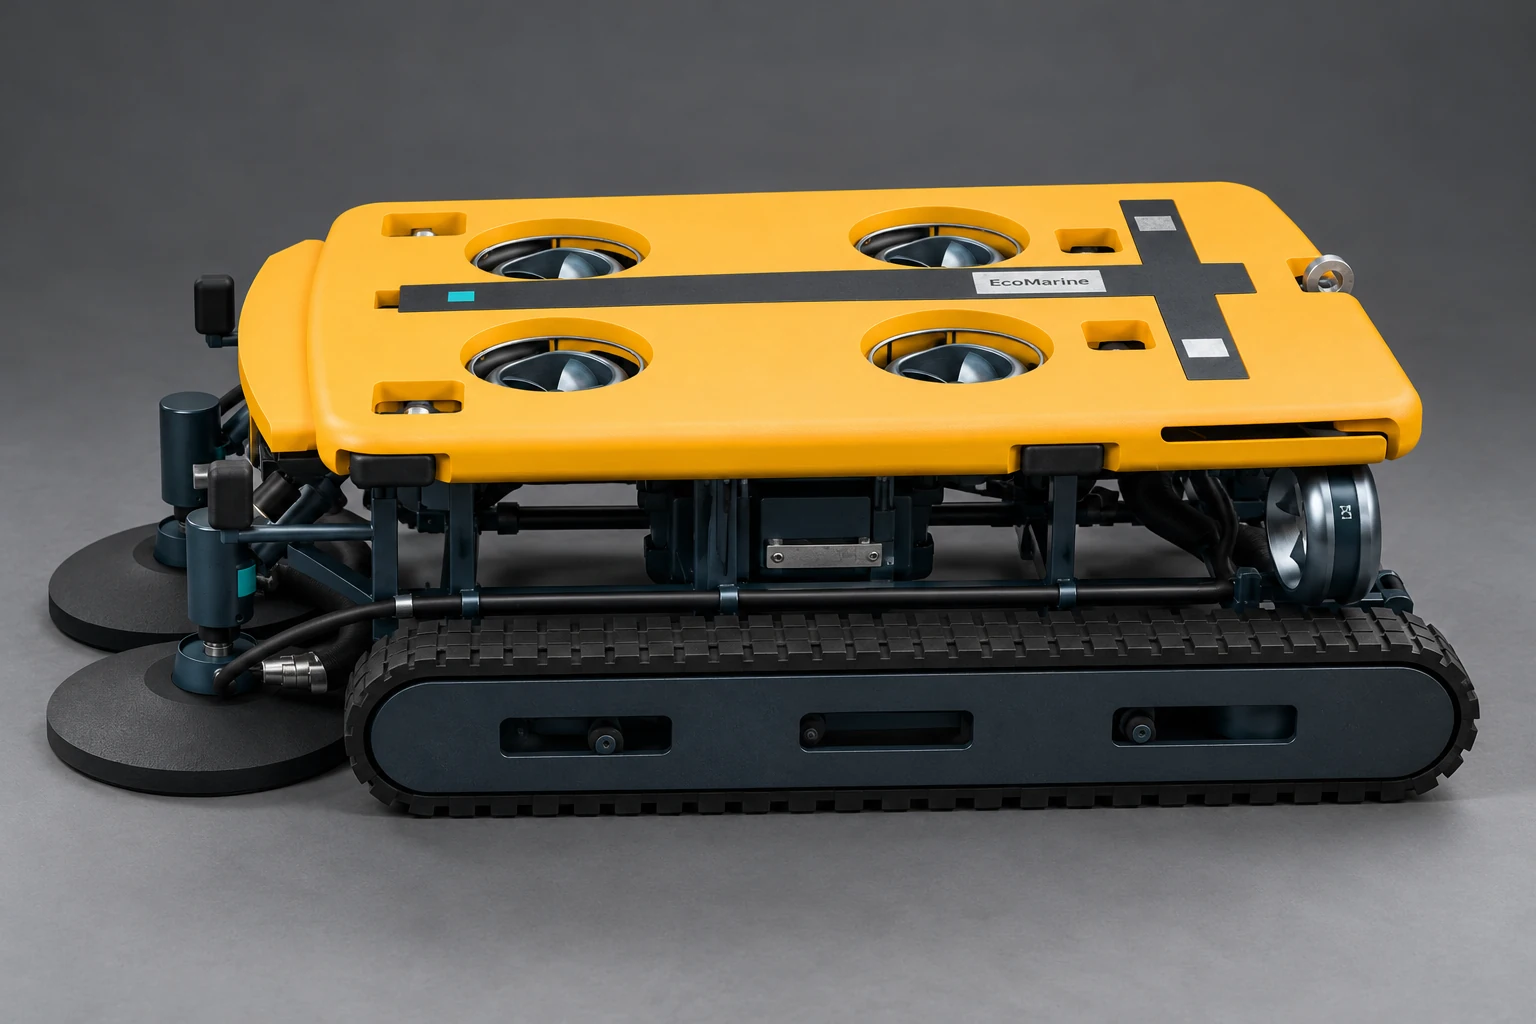
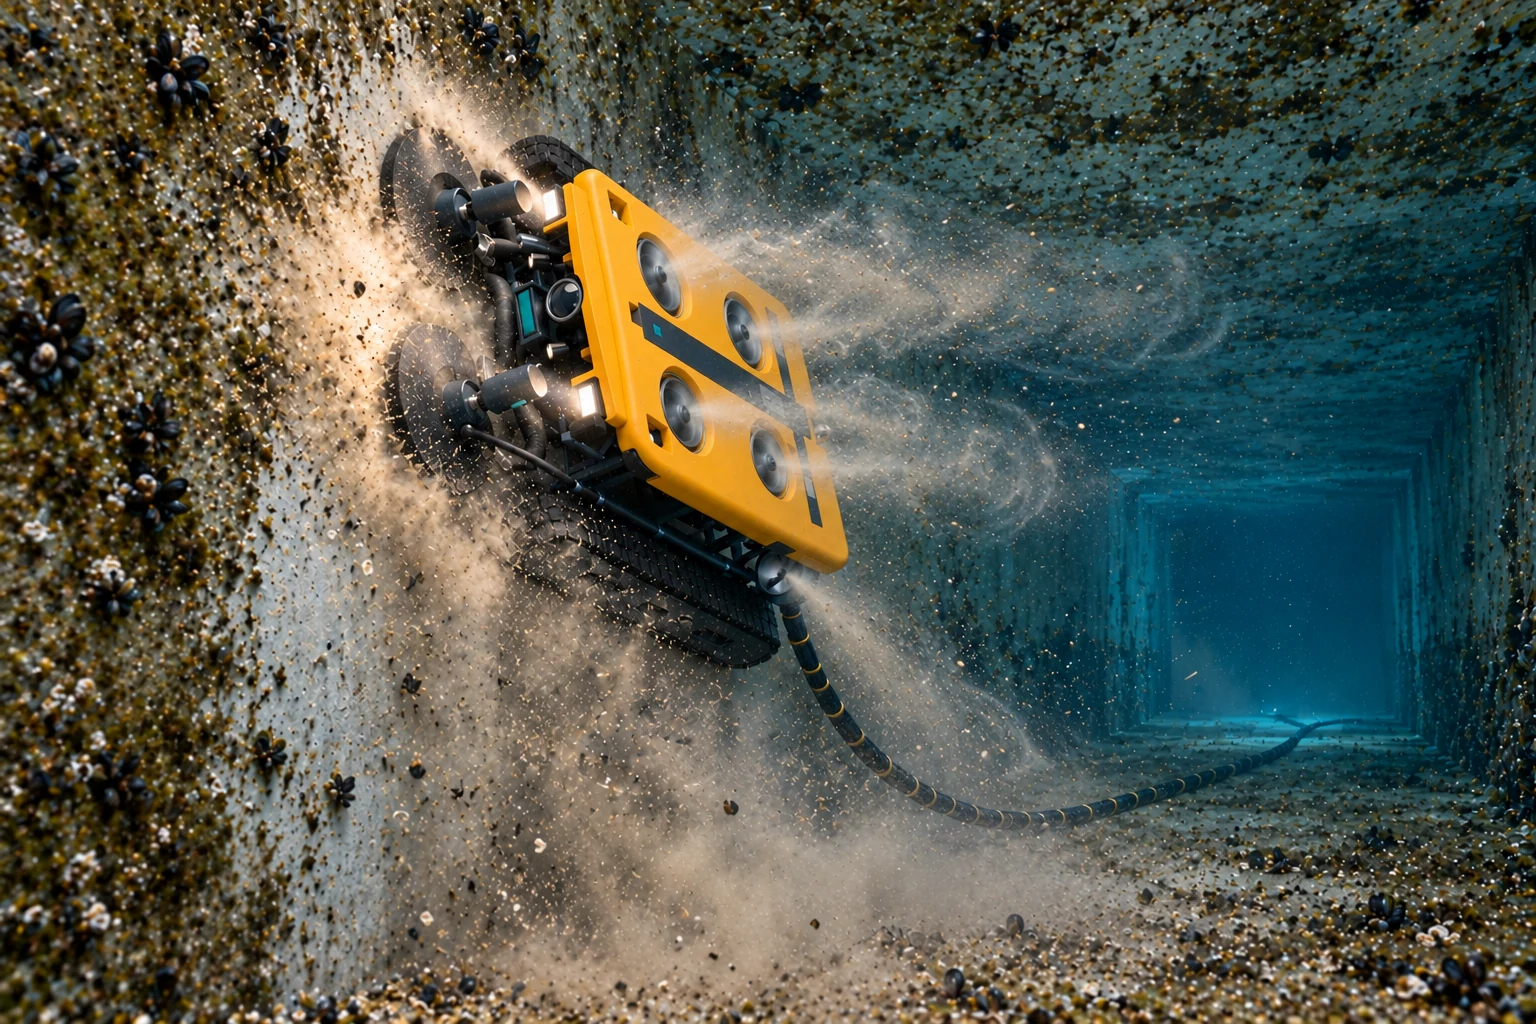
OmniBot is designed to hold against surfaces using EP1's sustained thrust, without magnetic attachment. This opens inspection and cleaning to concrete-lined underwater service tunnels and other non-magnetic structures, alongside vessel hulls. EP1 powers both maneuvering and attachment, giving the system flexibility across different underwater environments.
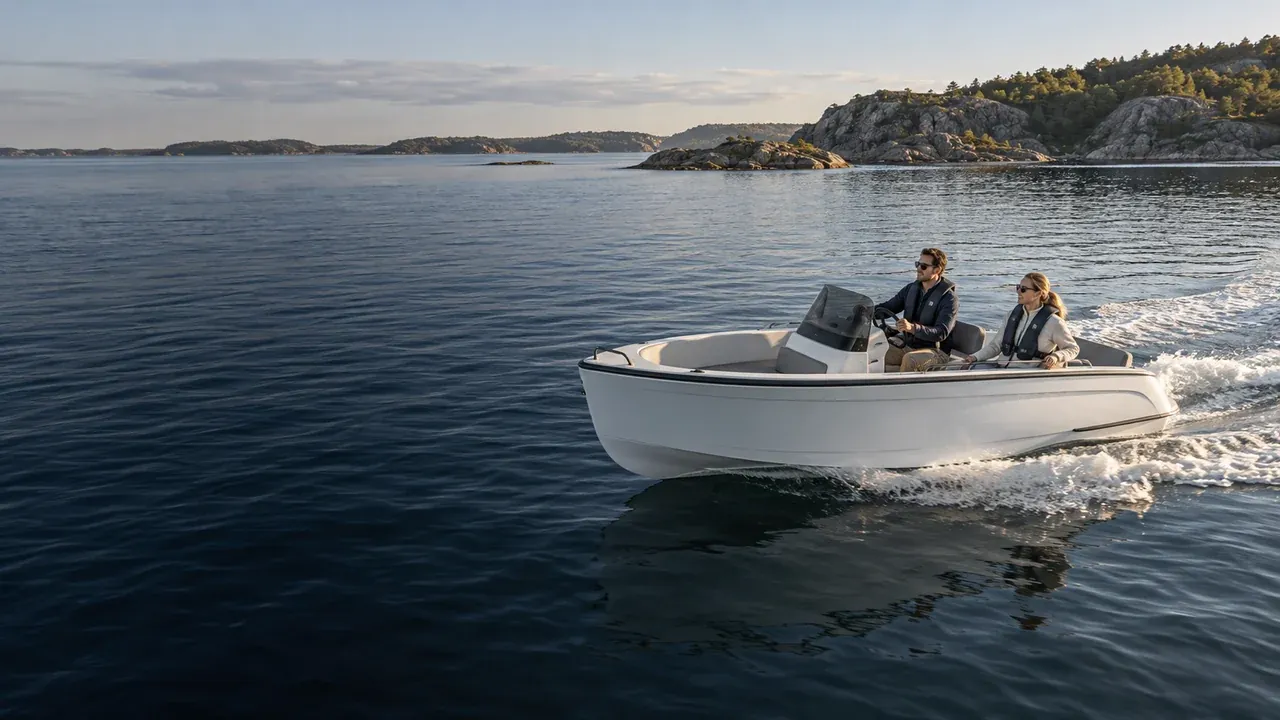
EP1 propulsion, now in a portable electric outboard for small boats and tenders. TERN 600 brings the battery, controls and motor together in one self-contained system.
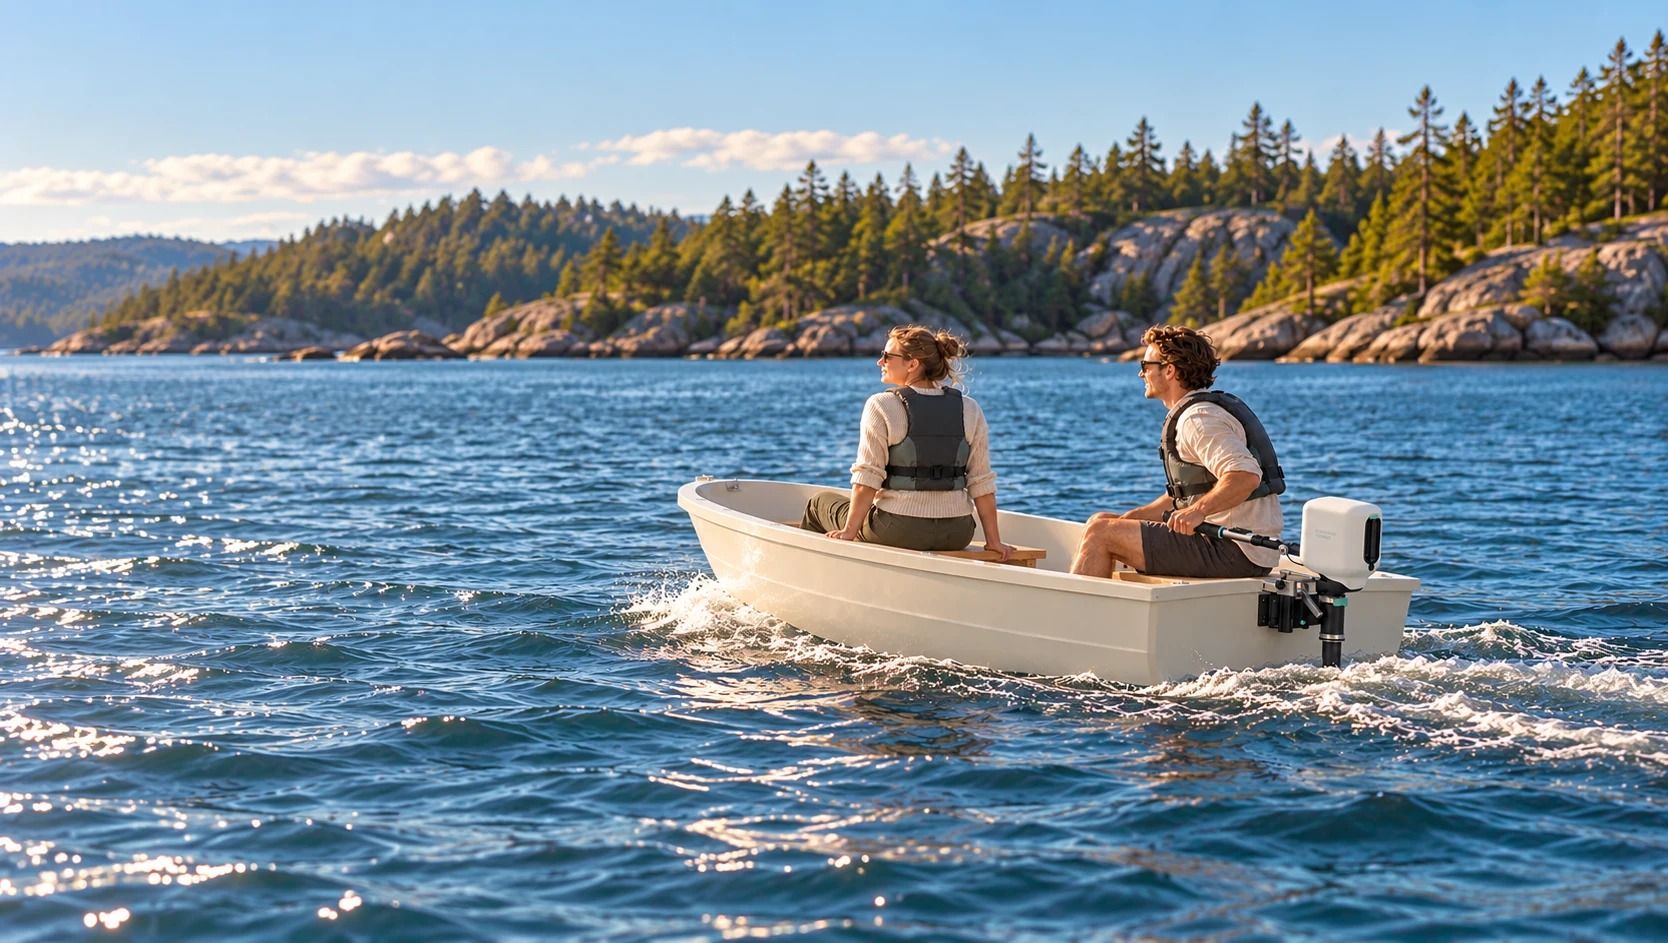
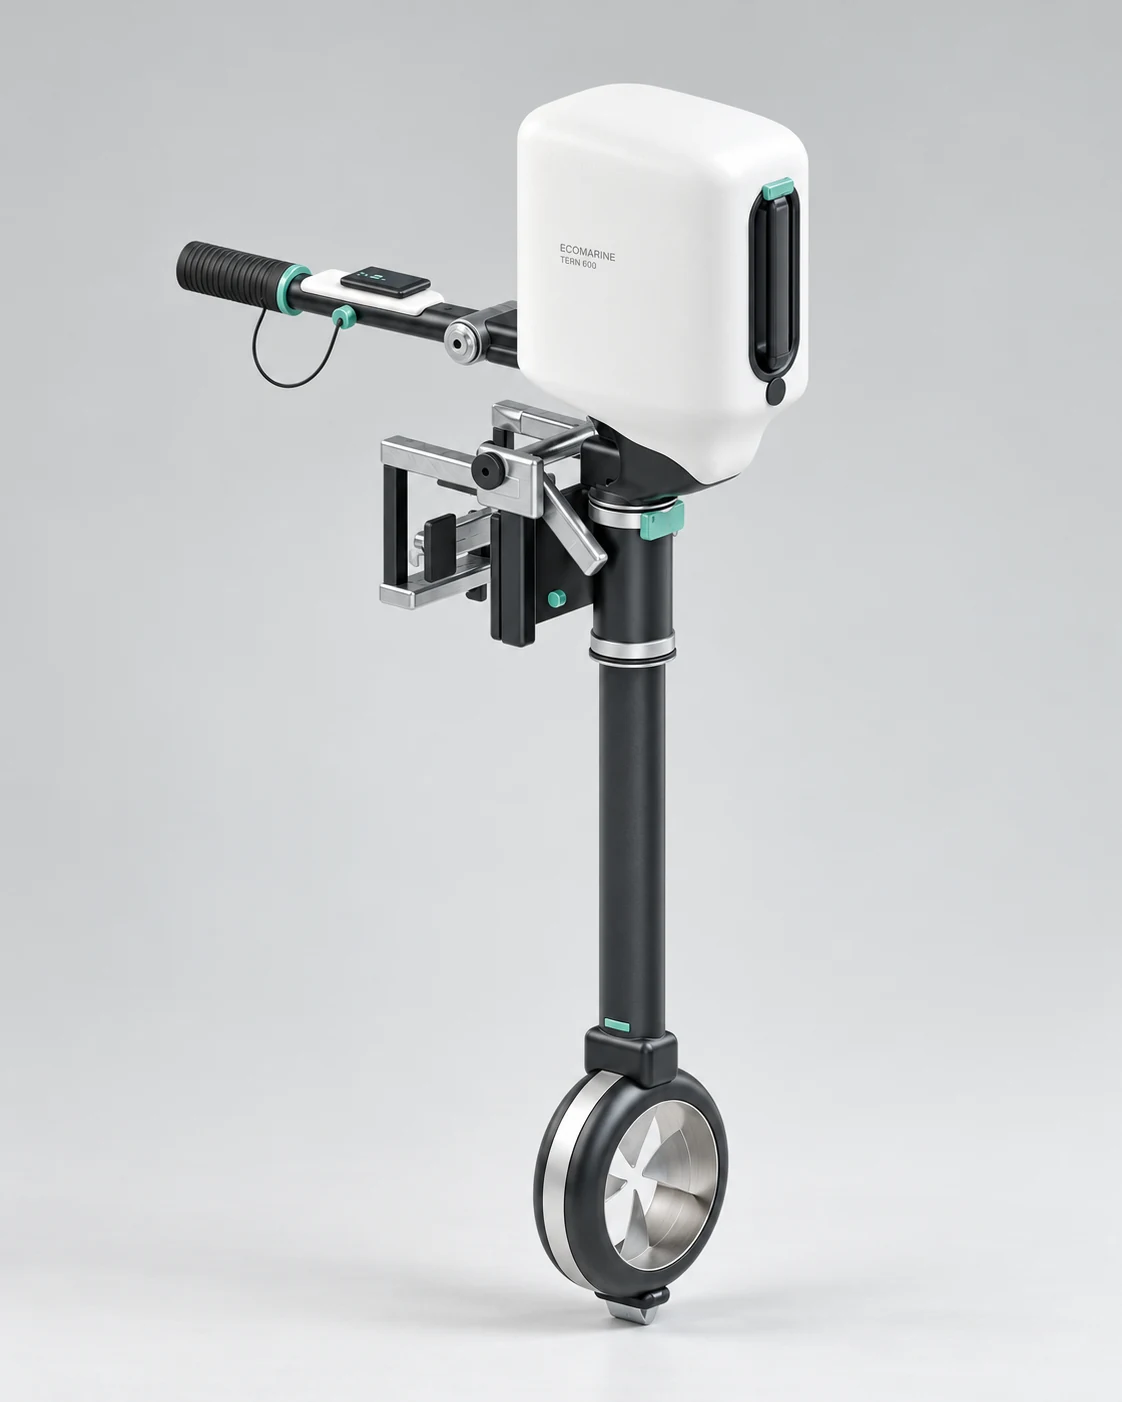
Inside the engineering. Out on the water.
Why we develop the axial-flux motor, shaftless rotor, blades and control as one propulsion system.
Read articleEP1 thrust-based attachment lets us develop one underwater robot for steel, concrete and composite structures.
Read articleSEATAC joined EcoMarine at COVE to capture close-up footage of OmniBot underwater.
Read articleWe are developing electric propulsion for useful work on and below the water. Tell us what your vehicle needs to do.