Non-magnetic attachment
EP1 thrust holds OmniBot against the surface without magnets, opening cleaning to concrete and composite structures as well as steel hulls.
OmniBot / Underwater inspection and cleaning
OmniBot is a remotely operated robot for removing heavy marine growth and inspecting underwater structures. EP1 thrusters let it swim between locations and press against surfaces, while tracks carry the cleaning and inspection tools along hulls and concrete tunnels.
OmniBot is a utility ROV that swims through open water and crawls along submerged structures. Our cleaning system tackles heavy biofouling, including marine growth such as barnacles and mussels.
Collection and filtration can be added to recover removed biomatter and separate it from the return water.
EP1 thrust holds OmniBot against the surface without magnets, opening cleaning to concrete and composite structures as well as steel hulls.
Cavitating water jets target marine growth without abrasive brushing. Cleaning settings are matched to the fouling, material and coating to protect the finish beneath.
Tracked movement carries the cleaning heads across large areas, helping reduce time on task and vessel downtime.
EcoMarine-developed EP1 thrusters provide strong thrust for maneuvering and attachment, with motor, blades and control developed together for efficient energy use.
Configure OmniBot for cleaning, inspection, or both. Modular tools let marine service teams adapt the robot to different vessels and underwater structures.
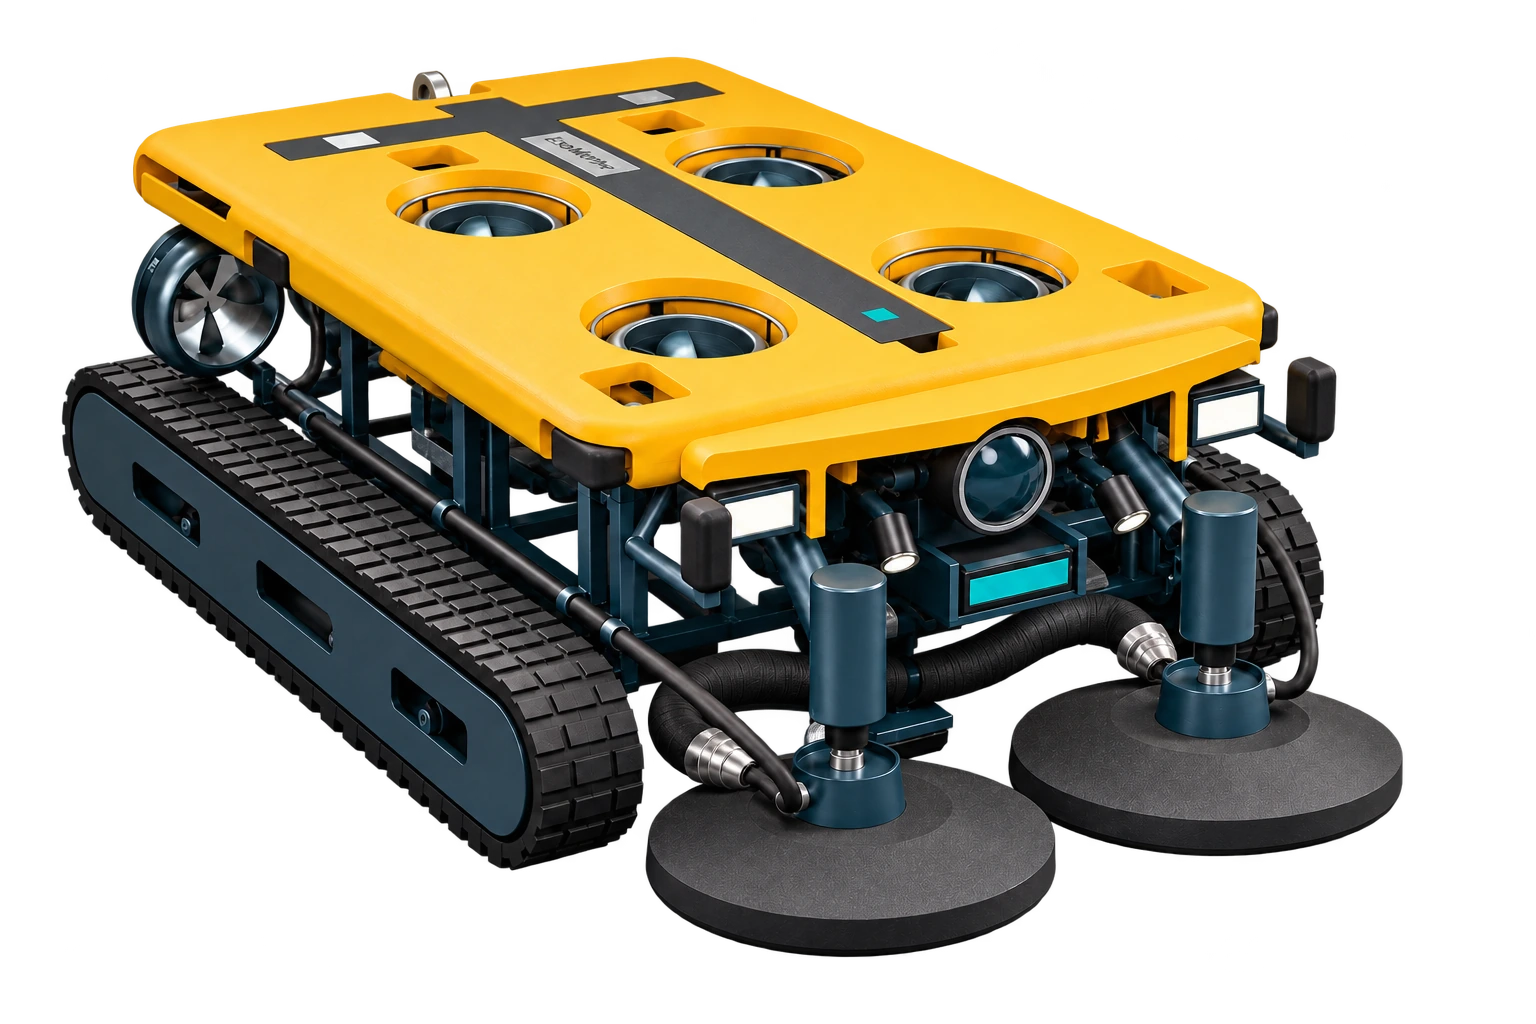
Use the live camera feed, lights and sonar to examine hulls and submerged structures and guide the robot where visibility is limited.
Paired water-jet heads are designed to remove heavy marine growth, including barnacles and mussels. Water supplied from the surface powers the cleaning jets while the tracks move them across the structure.
OmniBot needs thrust to move through currents and keep its tracks pressed against the structure while cleaning. We develop EP1 for strong, sustained thrust and efficient energy use, so propulsion supports both maneuvering and surface work.
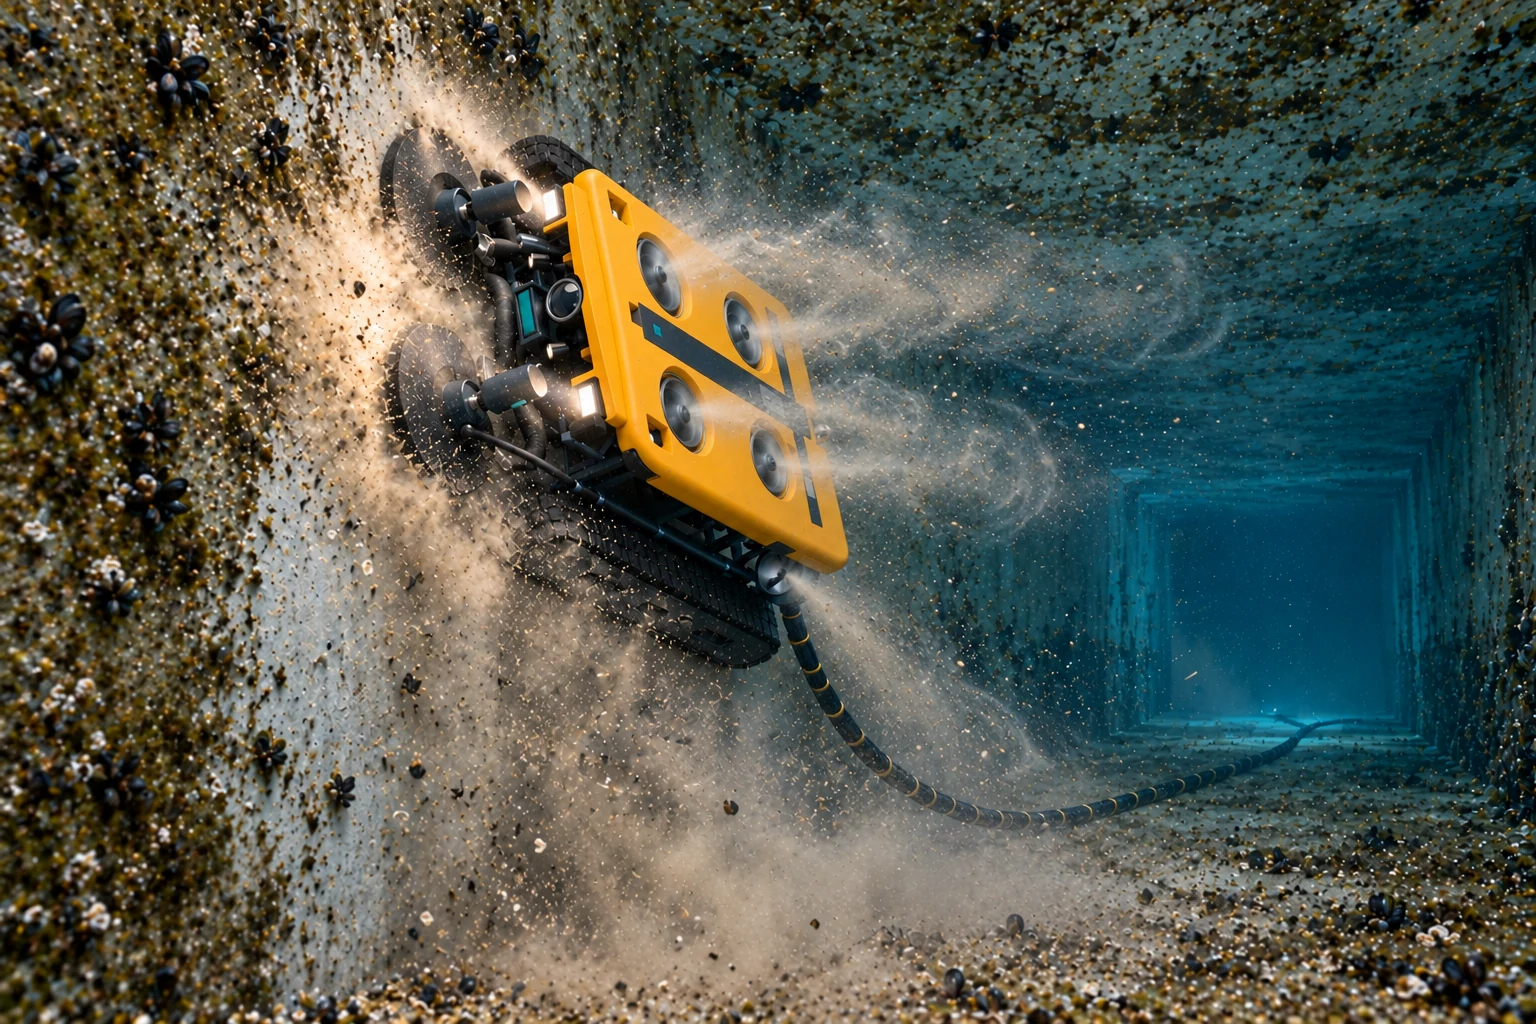
Rear EP1 thrusters provide directional thrust for approach and positioning around vessels, including in anchorages where the water is moving.
Four EP1 thrusters push the robot toward the surface. This supplies the force needed for track grip and helps keep the cleaning heads in position.
EP1's motor, blades and control are developed together for efficient continuous thrust during cleaning and maneuvering.
Tell us what needs cleaning or inspecting and where the work will take place. We can discuss the robot, tools and surface equipment suited to the job.
EP1 provides the thrust for swimming and attachment. Learn how its shaftless motor, propeller and control system are designed together.
Explore EP1 propulsion