How OmniBot cleans beyond steel hulls
EP1 thrust-based attachment lets us develop one underwater robot for steel, concrete and composite structures.
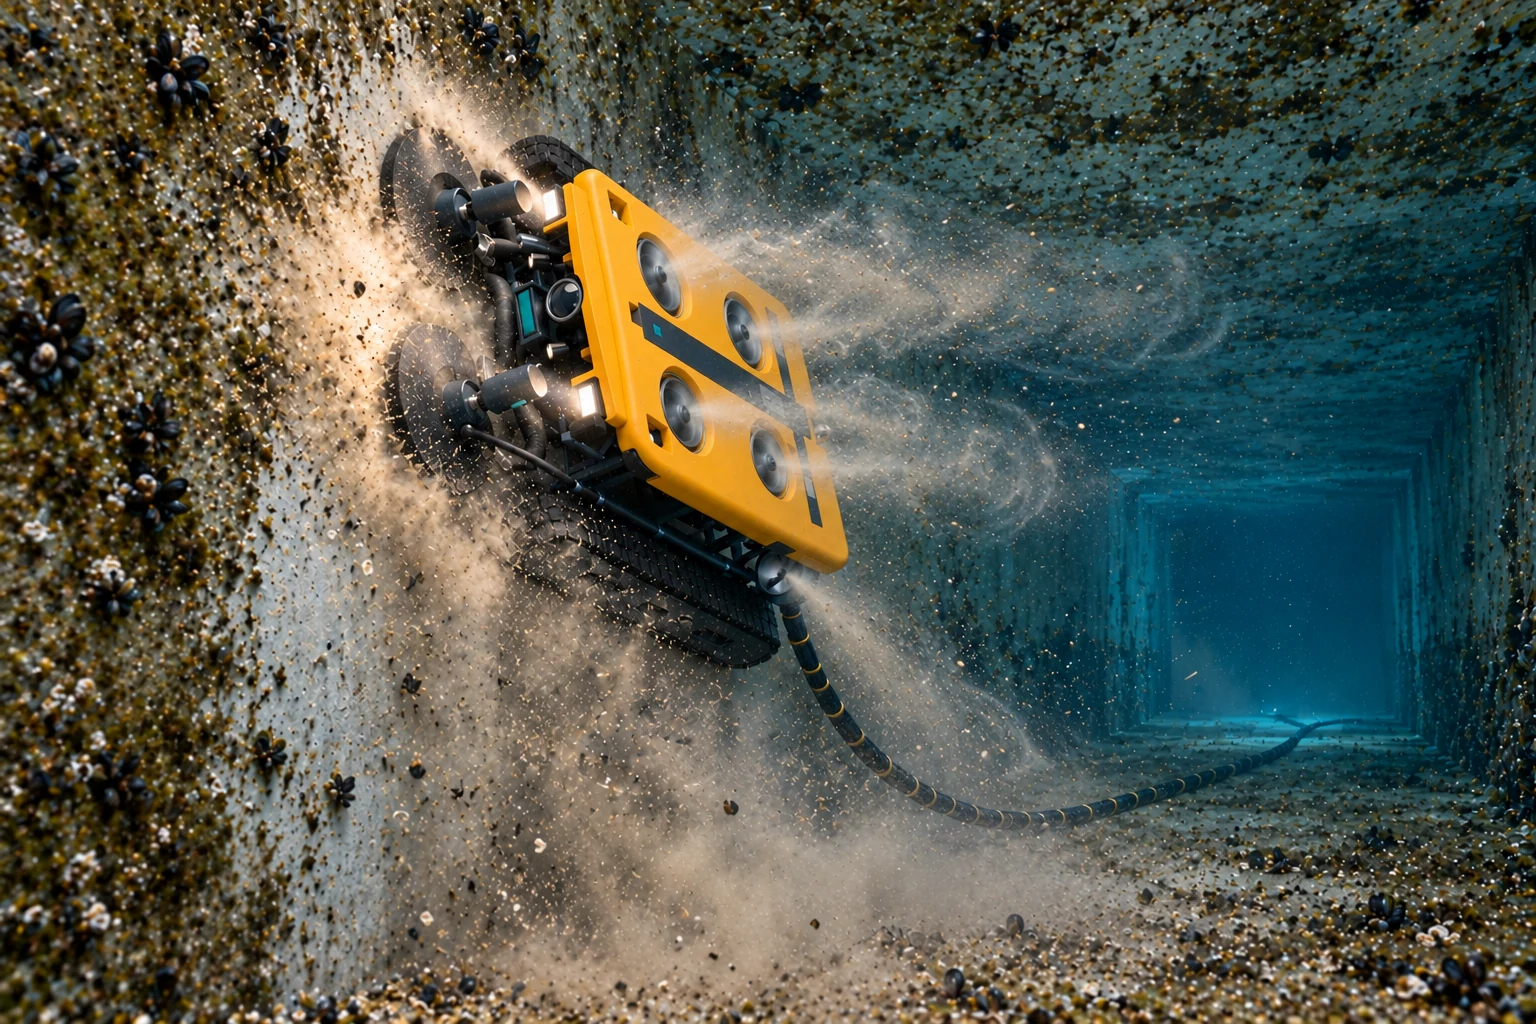
Underwater cleaning is a contact task. The robot must get to the structure, keep its tracks gripping and move its tools across the surface while water and tether loads act on it.
That is why EP1 is central to OmniBot's architecture. Propulsion supports both the journey to the work and the force used to stay against the structure.
Attachment without a magnetic surface
Magnets depend on the material beneath the robot. OmniBot uses EP1 thrust to press toward the surface, supplying contact force for the tracks without magnetic attachment.
This opens the design to concrete-lined underwater service tunnels and composite structures, as well as steel vessel hulls. The surface geometry, condition and operating environment remain part of how we configure the work.
Swimming and surface movement
Rear thrusters provide directional thrust for approach and positioning. Four surface-normal EP1 units supply force toward the structure and help control the robot's attitude.
The tracks turn that contact force into grip and movement. Together, propulsion and traction let the robot move through open water and then carry tools along a submerged surface.
Cleaning around the material
OmniBot's cavitating water-jet cleaning system targets marine growth without abrasive brushing. We match the cleaning settings to the fouling, surface and coating to protect the material beneath.
Surface equipment supplies the cleaning water. Collection and filtration can be added to recover removed biomatter and separate it from the return flow.
Inspect alongside cleaning
Modular camera and sonar attachments support underwater observation and positioning. This lets inspection and surface work share the same robotic platform.
Our design connects the full task: approach the structure, establish contact, move the tools and observe the surface. EP1's sustained thrust and efficient energy use support that sequence.